A tactile sensor detects physical contact and converts it into data on force, pressure, contact location, texture, or temperature, depending on its design. In robotics, that data lets a controller adjust grip strength, catch a slipping object, or tell a soft surface from a hard one before damage happens.
These sensors sit behind everyday tech, from touchscreens to surgical robots to prosthetic hands.
Robots increasingly pair this local contact data with 6-axis force-torque sensing at the wrist, two of the sensor types working together to handle objects they can’t fully see.
Unlike cameras, tactile sensors only gather information after contact occurs. That makes them essential for tasks where vision alone cannot determine whether an object is slipping, deforming, or being gripped with the correct force.
What Is a Tactile Sensor and How does it work?
Tactile sensors are designed to capture mechanical information when they come into contact with objects or surfaces, converting these physical inputs into measurable data.
This process is known as tactile sensing, where the sensor responds to variations in pressure or surface characteristics, allowing machines to “feel” their environment.
A tactile sensor is typically made of materials that can deform or change properties when a force is applied.
When the sensor surface is pressed, it registers the change, and this deformation is measured. The data gathered from this physical change is then transmitted as an electrical signal.
This signal is processed by a controller or microprocessor that translates the physical interaction into a command, such as clicking a button, grasping an object, or measuring the softness of a material.
The conversion of touch into measurable data occurs through various methods, depending on the type of tactile sensor. That signal keeps updating while contact continues, which is what lets a controller catch a slipping grip or stop the motion the instant it meets resistance it didn’t expect.
Tactile Sensors Vs Touch Sensors
Tactile sensors and touch sensors both detect physical interaction, but they differ in functionality.
Tactile sensors measure force or pressure applied to a surface, providing information about the intensity and nature of the touch, often used in robotics and medical applications.
Touch sensors, on the other hand, primarily detect the presence or absence of touch, typically relying on capacitive or resistive technologies, and are commonly used in smartphones and touchscreens.he two terms often overlap in practice; check the spec sheet, not just the name, to know whether a part reports a simple contact flag or a full pressure reading.
Types of Tactile Sensors
Tactile sensors can be classified either by their sensing principle or by their construction. The table below includes both, since engineers often encounter both naming conventions.
| Type | Sensing principle | Best fit |
| Capacitive | Capacitance change between electrodes | Touchscreens, robot skin, light-touch detection |
| Resistive | Resistance change under pressure | Control panels, automotive touch controls, low-cost arrays |
| Piezoelectric | Voltage generated by mechanical stress | Vibration, impact, dynamic force events |
| Optical | Light path or image change under contact | High-resolution fingertip sensing |
| Tactile pressure | Measurement goal, not a principle — can use any of the above | Full pressure or force mapping |
| Camera-based | Optical subtype: camera imaging a deformable gel layer | Delicate or irregularly shaped objects |
Capacitive Tactile Sensors
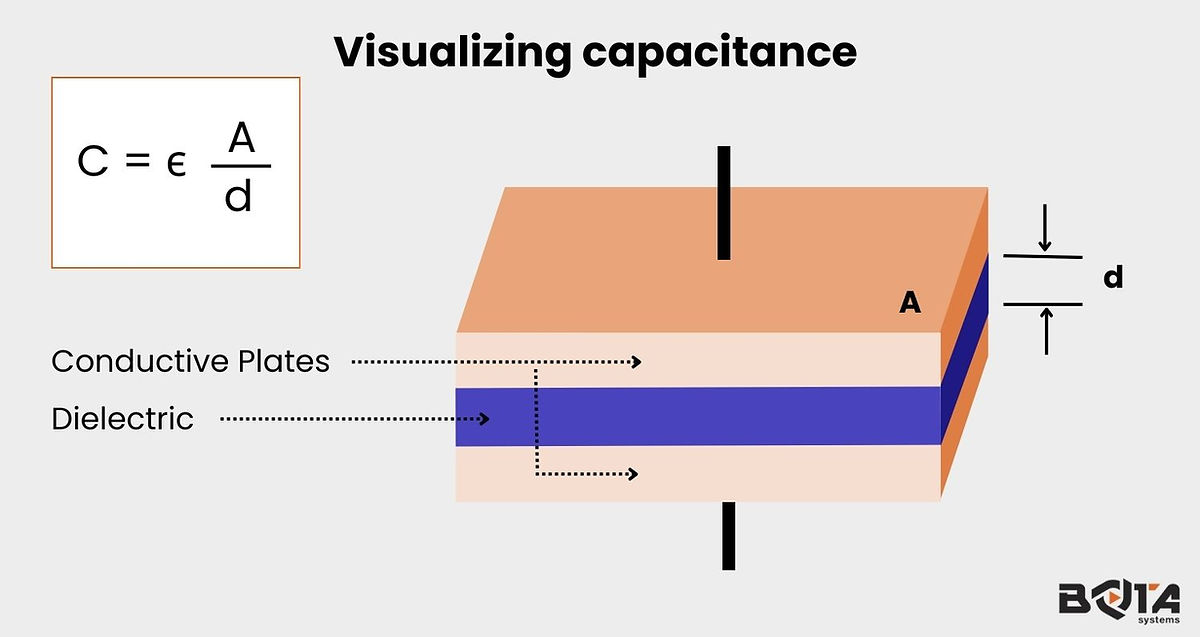
Capacitive tactile sensors consist of two electrodes separated by a dielectric material. When an object like a finger touches or presses the surface, the distance between the electrodes decreases, causing a change in the capacitance value.
This change is measured, and the system interprets it as touch or pressure. Capacitance (C) is measured by the equation:

Where ε is the dielectric constant, ‘A’ is the area of the electrode plates, and ‘d’ is the distance between the plates.
Capacitive sensors are widely used in mobile devices, touchscreens, and robotics for their high sensitivity and ability to detect light touches.
Resistive Tactile Sensors
Resistive tactile sensors work by detecting changes in electrical resistance when pressure is applied to the sensor surface. The sensor typically has multiple layers, including a conductive layer and a resistive layer.
When pressure is exerted, these layers come into contact, causing a decrease in resistance. The amount of pressure applied correlates with the change in resistance, allowing the sensor to measure the force precisely.
Resistance of a material is directly proportional to the length ‘L’ of the material and inversely proportional to the area ‘A’. The constant of proportionality, is called resistivity.

Resistive tactile sensors are typically used in Industrial control panels, automotive touch controls, and home appliances.
Piezoelectric Tactile Sensors
Piezoelectric tactile sensors rely on the piezoelectric effect, where certain materials (like quartz or ceramics) generate an electrical charge when subjected to mechanical stress.
When pressure is applied to the sensor, the piezoelectric material deforms, producing a voltage proportional to the force. The generated Voltage ‘V’ is proportional to the applied force ‘F’, with the equation:
V=kF
Where k is the piezoelectric constant.

These sensors are highly responsive to dynamic pressure changes, making them ideal for applications requiring precise force measurement such as medical devices, touchpads, and vibration detection systems.
Optical Tactile Sensors
Optical tactile sensors use light to detect pressure or touch. These sensors typically consist of a light source (such as LEDs) and a detector (such as photodiodes or cameras).
When pressure is applied to a surface, it causes deformations that alter the light path. The change in light intensity or reflection is detected by the sensor, which translates it into a measurement of force or pressure.
Optical sensors often use total internal reflection (TIR) or fiber optic networks, where the change in light intensity at the interface correlates with the applied pressure. These tactile sensors are used in precision-sensitive environments like surgical robots, industrial inspection, and high-end consumer electronics.
These specific technologies enable tactile sensors to measure varying forces with high accuracy, providing crucial feedback in devices and applications across multiple industries.
Each method trades off sensitivity, response speed, and durability differently, which is why the right sensor depends on the task.
Tactile Pressure Sensors
Tactile pressure sensors are specialized devices designed to measure force, pressure, or touch applied to a surface with high precision.
They are equipped with sensitive materials or mechanisms that convert physical pressure into electrical signals. These sensors differ from generic tactile sensors by focusing on quantifying the intensity and distribution of pressure across a surface.
They specialize in quantifying how hard or soft the contact is. While a tactile sensor may detect the presence of an object or surface characteristics, a tactile pressure sensor specifically measures the intensity or distribution of force over a given surface.
Tactile pressure sensors are designed to be highly accurate and these sensors provide real-time feedback, reacting almost instantaneously to pressure changes. This rapid response matters most in fast-changing applications, such as robotic grasping systems, where instant tactile feedback is necessary for adjusting grip force.
Camera-based tactile sensors
Camera-based tactile sensors utilize a camera to capture deformations in a soft gel layer when pressed against objects. Illuminated by LEDs, these deformations are recorded by the camera and analyzed by algorithms, providing detailed data on texture, shape, and force.
These sensors are valued for their high-resolution detail, adaptability, and cost-effectiveness, as they rely on readily available camera technology. This makes them ideal for tasks requiring precise feedback, such as handling delicate or irregular objects.
However, camera-based tactile sensors have certain limitations. Processing high-resolution images can introduce latency, the gel layer may degrade under heavy use, and their bulkiness can complicate integration into compact systems. They are best suited for applications where detailed tactile information is prioritized over response speed and long-term durability.

Tactile sensor vs. force-torque sensor
A tactile sensor and a 6-axis force-torque sensor solve different parts of the same contact problem, and robots typically use both rather than choosing one.
A tactile sensor reports pressure spread across a surface, usually at a fingertip. A force-torque sensor reports a single reading instead: net force and torque through one point, usually a wrist or tool flange.
A gripper might feel where an object sits at the fingers while a wrist sensor tracks the total load, the number that matters for polishing, assembly, or stopping on unexpected resistance.
| Tactile sensor | 6-axis force-torque sensor | |
| Measures | Contact spread across a surface | Net force and torque at one point |
| Typical location | Fingertip, gripper pad | Wrist, tool flange |
| Answers | Where contact is, and whether it’s slipping | How much load the arm is carrying |
Applications of Tactile sensors
The information a tactile sensor provides depends on where it’s mounted. Fingertip sensors help robots manipulate objects, while larger tactile arrays can detect pressure distribution across an entire surface.
Tactile sensors have a wide range of applications across various fields due to their ability to measure force, pressure, and texture.
Medical Applications:
Prosthetics: Tactile sensors are integrated into prosthetic limbs to provide feedback on grip strength and object manipulation, enhancing the user’s control and functionality.
Surgical Tools: They are used in minimally invasive surgical instruments to provide surgeons with real-time feedback on tissue pressure, improving precision during operations.
Patient Monitoring: Tactile sensors can monitor patient movement and pressure on beds or chairs, helping prevent pressure ulcers and ensuring patient safety.
Industrial Automation:
Quality Control: Tactile sensors are employed in manufacturing to inspect products for defects by measuring the force required to deform or manipulate them.
Robotic Grippers: Used in robotic arms, these sensors enable precise control over gripping force, allowing robots to handle delicate objects without causing damage.
Assembly Lines: They help automate assembly processes by detecting the correct alignment and pressure during component fitting.
Robotics:
Humanoid Robots: Tactile sensors enable robots to perceive their environment, providing feedback for tasks like object manipulation, walking, and navigating complex terrains.
Collaborative Robots (Cobots): These sensors allow cobots to work safely alongside humans by detecting touch and adjusting their actions based on the proximity and pressure of human interaction.
Automotive Applications:
Driver Assistance Systems: Tactile sensors are used in steering wheels and dashboards to detect driver touch and enhance user interaction with infotainment systems.
Safety Features: They can detect the presence and weight of passengers in seats, adjusting airbag deployment strategies based on occupant characteristics.
Touch-sensitive Controls: Integrated into vehicle surfaces, these sensors allow drivers to interact with controls without needing mechanical buttons.
Research and Development:
Material Testing: Tactile sensors are used in laboratories to analyze the mechanical properties of materials by measuring their response to applied forces.
Human-Robot Interaction Studies: Researchers use tactile sensors to study how robots can safely interact with humans in shared environments, improving design and functionality.
Which modality matters most, force, pressure, texture, or temperature, depends entirely on the task in front of the robot.

Tactile sensing and force-torque sensing at Bota Systems
Bota Systems’ core line is 6-axis force-torque sensing. Its tactile sensing platform extends that to the fingertip: sub-0.01 N sensitivity, contact event recognition, and slip detection, feeding Physical AI control loops built for grip-force optimization.
Fingertip data tells the gripper what’s happening at the point of contact; the wrist sensor tells the arm what it’s carrying overall.
The right sensing setup depends on the object, grip forces, robot payload, required sensitivity, and control-loop speed. Engineering teams can discuss tactile sensing for their application to determine which sensor configuration fits their robot and contact task.
Conclusion
In conclusion, tactile sensors, particularly tactile pressure sensors, play a pivotal role in modern technology, enabling machines to perceive touch and pressure much like humans.
With diverse types, such as capacitive, resistive, piezoelectric, and optical sensors, each designed for specific applications, these sensors enhance accuracy, responsiveness, and adaptability across various industries.
As technology continues to evolve, the significance of tactile sensors in shaping the future of robotics and automation will only grow, paving the way for more intuitive and responsive devices.